OUR STARTING POINT
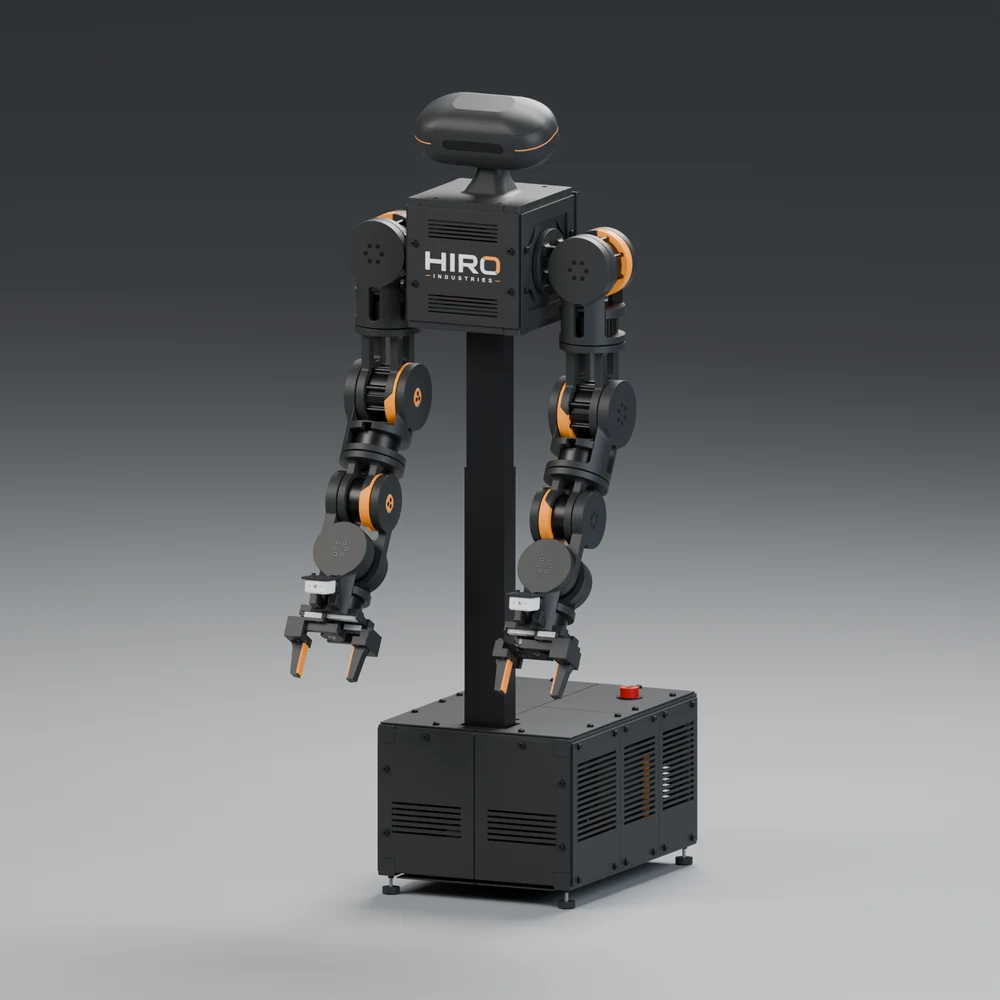
Meet Origin.
A stationary, dual-arm robot built around human workstations. Its two arms, adaptable grippers and multiple camera viewpoints create a versatile foundation for physical work. Packing, kitting and light assembly are examples of where that foundation can lead.
01Let the task lead.
Build the capability a job requires, then learn from the work.
02Work closely.
Understand the station alongside the people who know it best.
03Earn the next step.
Measure quality, useful output and human assistance before expanding scope.
THE FOUNDERS
Built by people
who build robots.
COFOUNDER / CEO
Lex Roller
Lex leads product, hardware engineering and company direction at HIRO. His work spans electrical systems, perception, autonomy and hands-on robot development, including industrial automation at Hampton Lumber and robot platforms at Nori Robotics.
COFOUNDER / CTO
Ethan Marreel
Ethan leads controls, compute and software at HIRO, connecting robot hardware with the systems that make it useful. His background includes AI, machine learning and tactile robotics research with Oregon State’s DRAIL lab, alongside software development and prototyping.
CORVALLIS, OREGON
Close to the work.
Open to what's next.
We're building HIRO in Oregon, starting with the manufacturers and teams around us. Our long-term ambition is to make useful physical labor more abundant. Origin is where we begin.
Explore a partnership ↗